Multi-UAVs formation control project
Published:
Preface
This project was completed during the first semester of my Master 2 program in Smart Aerospace and Autonomous Systems, shortly after I arrived in France. I have been interested in formation control for a long time, but only recently had the opportunity to study it in depth. Therefore, this project was developed both as a way for me to practice consensus control and to gain a complete understanding of the control pip eline for drones. Most of the formation control knowledge I acquired comes from the book 1, while the translation-scaling formation control approach is based on 2. All the control systems I designed were implemented in Python and simulated using MuJoCo. The project is public on my GitHub here.
My contribution
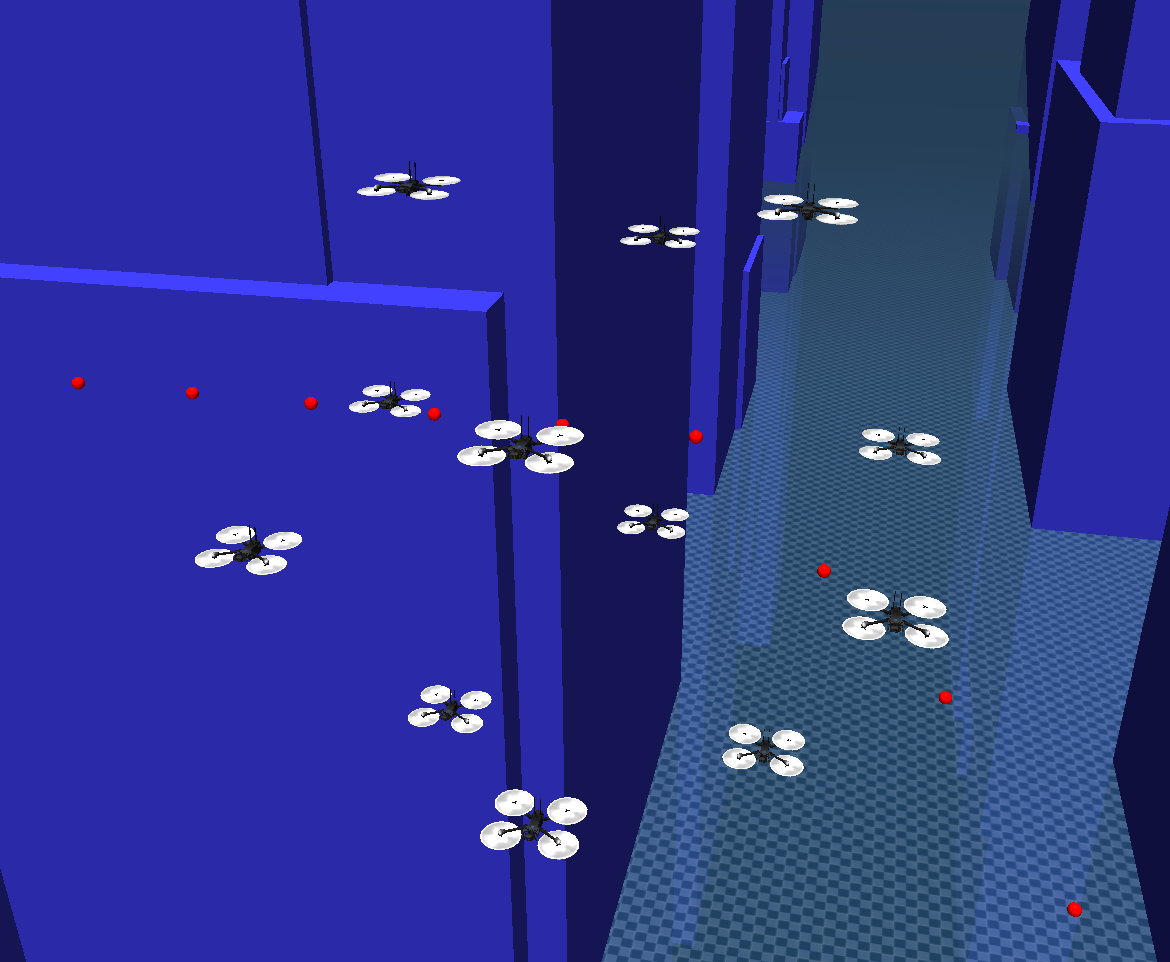
- Consensus algorithm is use for formation control. I use the bearing-based approach. Also I ensure the collision avoidance between agents.
- Developed an A* path-finding algorithm for static obstacle avoidance and path finding.
- A low-level thrust PID control for quadcopter.
- Documented the system architecture and algorithms, providing clear guidelines for the project.