Multi-objective Particle Swarm Optimization project
Published:
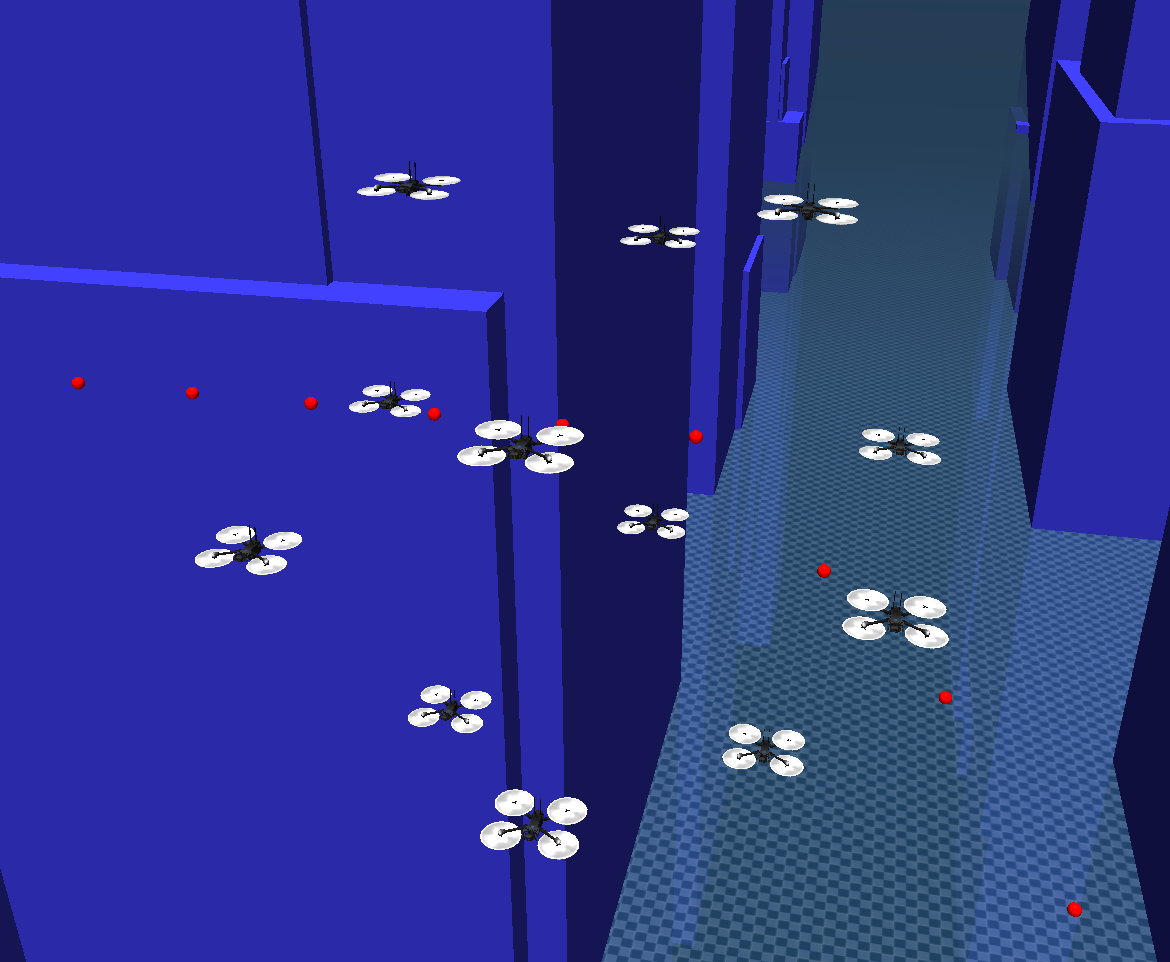
This is one of my project in the Taiwan internship.
Published:
This is one of my project in the Taiwan internship.
Published:
This thesis is my main research at the Department of Automation, School of Electrical Electronics, Hanoi University of Science and Technology (HUST).
Published:
This is one of my project at MEG after finish my graduation thesis.
Authors: Nguyen Viet Khanh, Minh Do Duc, Thanh Cao Duc, Lam Nguyen Tung
Published in IET Cyber-Systems and Robotics (SCIE Q3), 2024
This paper proposes a flatness-based trajectory planning and tracking control method with an integrated extended state observer to suppress liquid sloshing.
Authors: Nguyen Viet Khanh, Hue Luu Thi, Duc Thanh Cao, Nguyen Tung Lam, Duc Minh Do, Vo Thanh Ha
Published in The 9th International Conference on Applying New Technology in Green Buildings (ATiGB), 2024
This paper proposes a control strategy for liquid transfer on a Mecanum-wheeled mobile robot platform, addressing motion stability and sloshing reduction.
Authors: Nguyen Viet Khanh, Hue Luu Thi, Duc Thanh Cao, Dang Huu Bang, Nguyen Tung Lam
Published in 2024 International Conference on Advanced Technologies for Communications (ATC), 2024
This paper analyzes the non-flatness property of liquid sloshing dynamics and proposes an approximate approach for control and trajectory planning.
Authors: Nguyen Viet Khanh, Hue Luu Thi, Thanh Cao Duc, Nguyen Danh Huy, Vu Minh Nhat, Nguyen Tung Lam
Published in IEEE Access (SCIE Q2), 2025
This paper presents a time-optimal motion planning and anti-sloshing control strategy for containers under external disturbances.
Authors: Nguyen Viet Khanh, Hue Luu Thi, Minh Do Duc, Thanh Cao Duc, Nguyen Danh Huy, Nguyen Tung Lam
Published in 3rd International Conference on Advances in Information and Communication Technology (ICAICT, Scopus Q4), 2025
This paper presents an anti-sloshing control strategy by integrating input shaping with Lyapunov-based model predictive control.